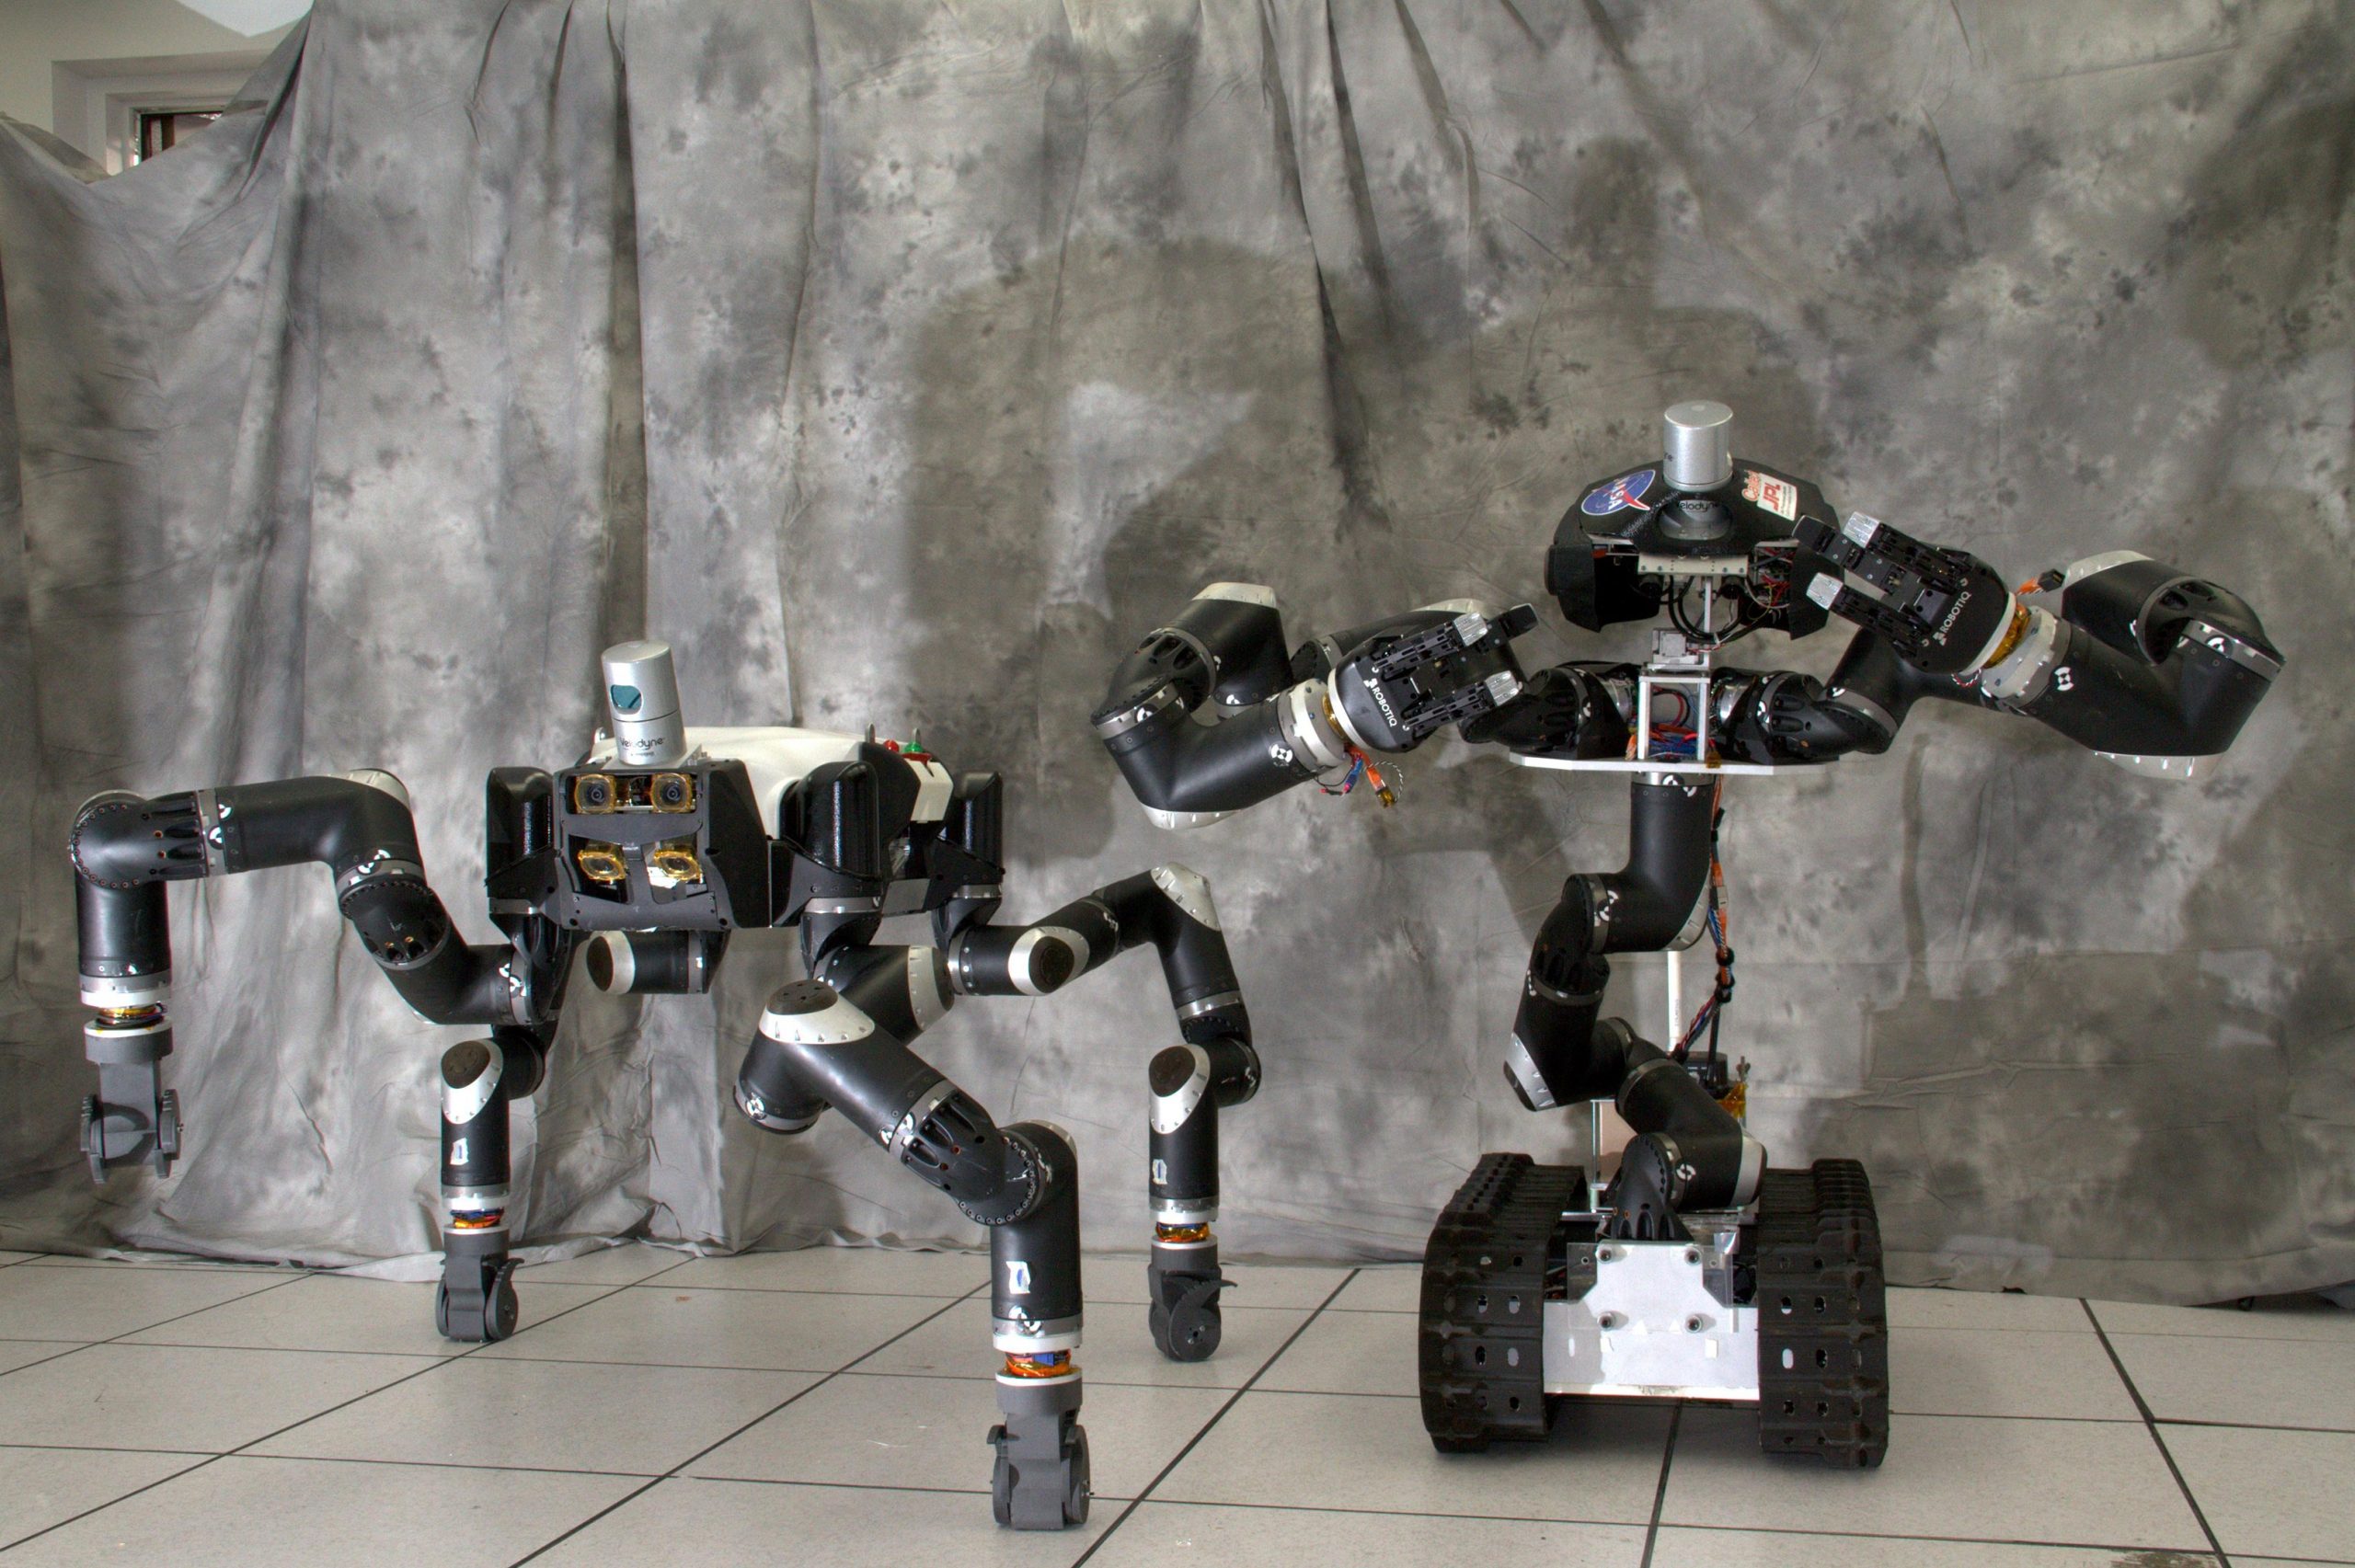
The RP1 platform integrates mechanical structures, electronics, and ROMOMO actuator technology with a cohesive software suite dubbed PartyOS. Unlike closed systems, this architecture allows teams to trace physical output directly to specific training models and control algorithms. When experimental results deviate from expectations, researchers can modify the underlying hardware or adjust control feedback loops to isolate and resolve systemic issues.
RoboParty offers two distinct configurations tailored for specific research needs. The Standard model stands 1.3 meters tall with 24 active degrees of freedom, while the RP1 Pro expands this to 30, incorporating a two-axis neck and seven-axis arms for complex interaction tasks. Both versions feature modular wrist-mounted effectors and interchangeable heads, enabling teams to swap components as their experimental requirements evolve. By treating the entire stack as a transparent foundation, RoboParty provides a shared environment where engineering choices and hardware modifications remain fully documented and repeatable.

Comments (0)
No comments yet. Be the first!